What I build
I build systems that cross the boundary between code and hardware: FPGA pipelines in Verilog/VHDL, ESP32 and Raspberry Pi firmware, sensor-driven devices, and robots running ROS 2. I'm drawn to problems where timing, perception, data movement, and control have to work together.
My projects range from a Jetson Orin Nano drone and collaborative LiDAR mapping to a real-time FPGA Sobel edge detector, predictive goalkeeper, IoT medicine box, and market-data services in Java/Spring Boot. I also build full-stack applications, moving comfortably from device to backend.
Selected work
Autonomous Drone Platform
2026In progressA vision-guided quadrotor for GPS-denied flight, built around a Jetson Orin Nano and an Orbbec Gemini 336 depth camera on a laser-cut carbon fibre airframe. Final year project, in progress.
- Jetson Orin Nano
- ROS 2
- Orbbec Gemini 336
- C++
- Python
ASCILAM: Collaborative Multi-Robot SLAM
2025CompleteTwo low-cost LiDAR scouts stream scans and odometry over micro-ROS to a Raspberry Pi coordinator that merges them into one live occupancy map. Two scouts explored faster than one.
- ROS 2 Foxy
- micro-ROS
- ESP32
- Arduino
- LD19 LiDAR
Real-Time Sobel Edge Detection on FPGA
2026CompleteA camera-to-VGA edge detection pipeline in Verilog on a Basys 3, with a streaming Sobel core that outputs one pixel per clock at 640×480, verified bit-exact against a NumPy model.
- Verilog
- Vivado
- Basys 3 / Artix-7
- OV7670
- VGA
The lab
Three pieces you can operate rather than read about. Each runs in the browser, on its own route, and none of them loads until you ask.
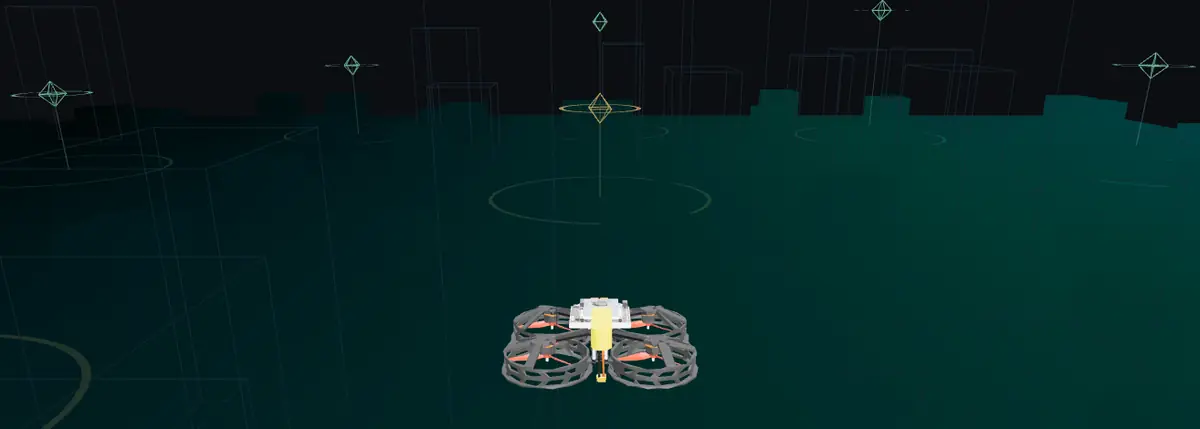
Flight Experience
- Scene
- Explore Projects Virtually
- Controls
- WASD · arrows for altitude and yaw
Or read the same nine zones as plain pages.